Instrument data
Calibrated instrument sensing can describe the tool's motion and load—if they are calibrated against a known setup.
Surgical Instrument Research
Styx is an early research concept for capturing the relationship between instrument motion, contact force and the visible surgical field.
The first system is deliberately modest: controlled training materials, instrument data, synchronized video, and a clear record of what the instrument actually did.
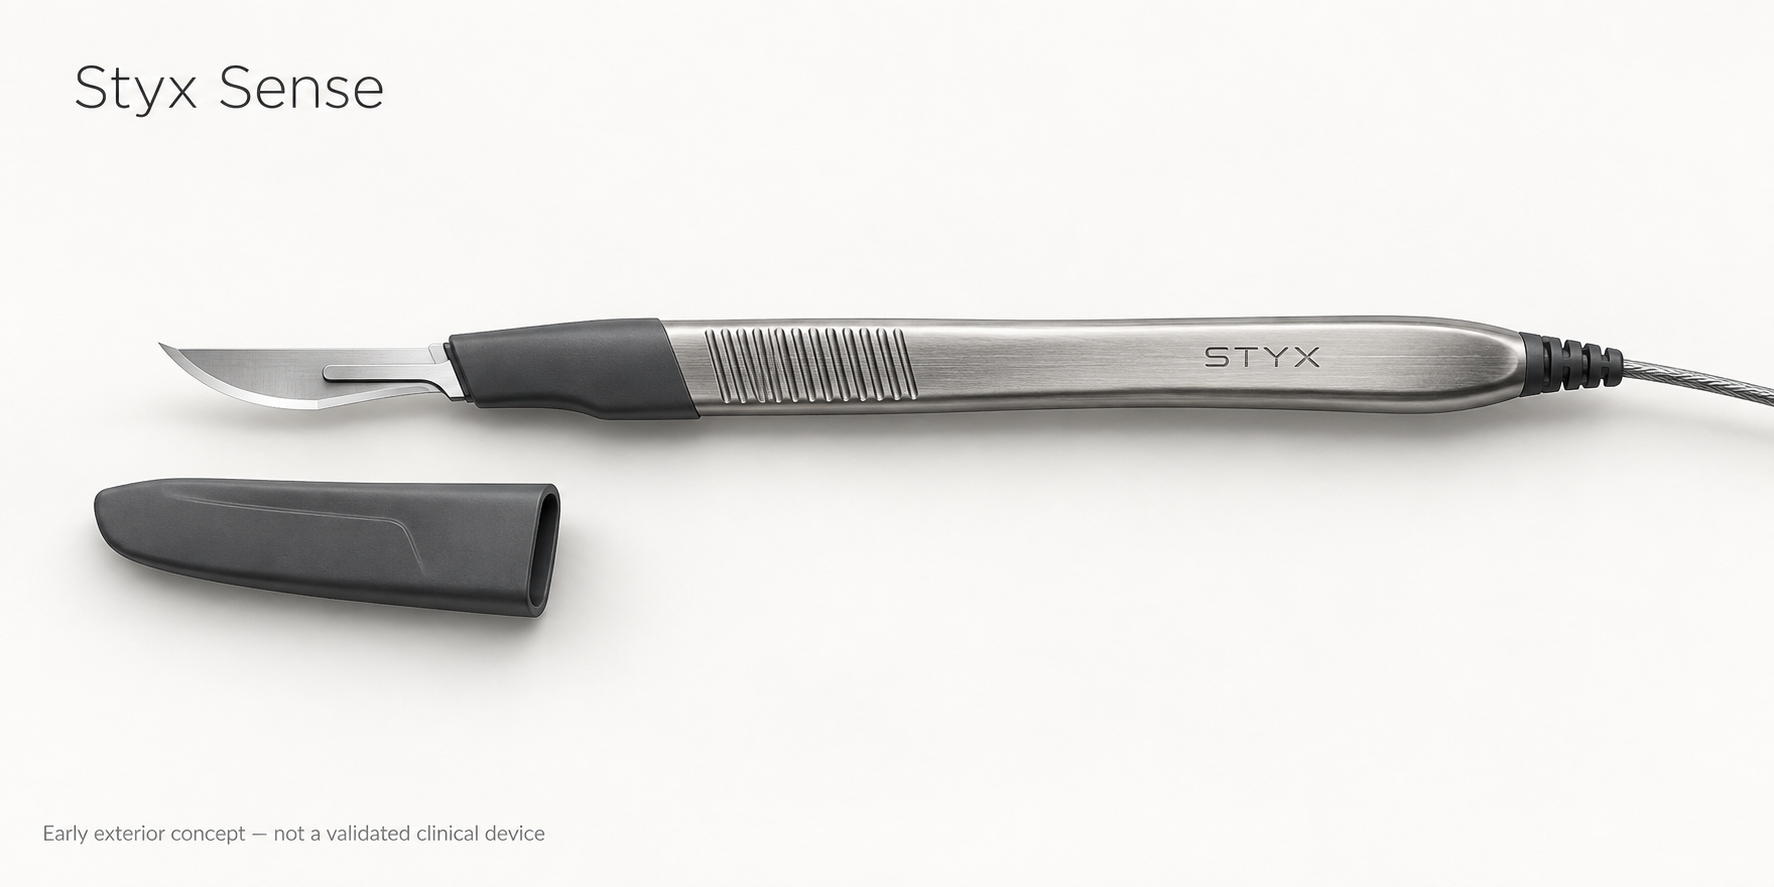
Video can show where a blade appears to be. It cannot always reveal the force at the handle, the hidden tip, the tissue response, or the operator's intent. Styx is exploring whether a small set of calibrated signals can make those moments easier to study.
Calibrated instrument sensing can describe the tool's motion and load—if they are calibrated against a known setup.
Multi-angle video preserves the scene around the tool. Close-up views help, but appearance alone is not ground truth.
Every output should carry its uncertainty, calibration method and limits. The first job is to learn what is useful—not to claim clinical accuracy.
Capturing instrument data alongside the surgical field, so researchers can study what video alone cannot show.
Surgical Instrument Research is in development, with performance still to be validated. Not offered for clinical use.
Our first camera experiments explore what a close view of the instrument can add to an external view of the setup. Early test materials help us study visibility and movement.
Selected 14-second excerpts from our September 2026 bench tests, cropped and rotated for viewing, with audio removed. Clips play independently. These recordings explore capture feasibility; they do not establish measurement accuracy or wound depth.
The first build can leave the electronics outside the handle. That makes the load path, wiring, calibration and data quality visible to a reviewer. Miniaturization comes only after the signal earns its place.
04 / START A CONVERSATION
The most useful next conversation is with someone who can point to a task where measurement, annotation or repeatability is genuinely expensive.
For research partnerships, technical review or early collaboration:
beckett.dillard@gmail.com